Senior Autonomy Engineer · London
I build robots that see, learn and work in the real world.
Robotics and computer vision engineer. I take perception and robot learning from research to machines that run in the field, from heavy equipment to dexterous hands.
- 50% → 77%success plugging a connector with under 1 mm clearance, once operators could feel contactHaptic feedback · Extend Robotics
- 3% → 0.4%genuine users wrongly rejected by on-device face login, at one-in-a-million false acceptsVFace · Veridium
- 2.1×more correct matches in the auto-approved bucket, so human QC goes where it mattersUncertainty QC · Augmodo
- 100Krobot camera images turned into training data with zero hand labelsSelf-supervised spray targeting · Q-Bot
selected projects · robotics × vision × learning
Where perception and learning meet real machines.
Simulation & perception for heavy machinery
Isaac Sim and MuJoCo twins of forklifts, wheel loaders and dozers, a fused camera-depth perception pipeline, and a see-through bucket view for operators.
- target cut in truck-loading cycle
- 10–15%
- machine types simulated
- 3
Full-stack robot learning & Haptic-ACT
The full robot learning backend, from VR demonstration through AWS training and serving to real-time policies on Jetson Orin, for ACT, GR00T N1.6 and π0. Plus Haptic-ACT, force feedback for gentler manipulation (IEEE IROS 2025).
- MSD plugging success with haptic feedback (teleop)
- 50% → 77%
- lower avg fingertip force vs ACT, real robot
- ~15%
Self-supervised spray targeting & auto-drive
A U-Net trained on years of operator behaviour, with no hand labels, that tells Q-Bot's Mk7 spray robot where to insulate next and lets it drive there on its own. First-author paper at IEEE MMAR 2022.
- spray-region mIoU, up from 0.645
- 0.706
- on-site images, zero hand labels
- 100K
experience
Where I've shipped.
- Jul 2026 – nowHive AutonomySenior Autonomy EngineerPerception, simulation and teleoperation for autonomous heavy machinery: forklifts, wheel loaders and dozers.
- Oct 2025 – Jun 2026AugmodoSenior Computer Vision EngineerRetail shelf intelligence from video: what is on the shelf, what should be, and what is missing.
- Jul 2024 – Sep 2025Extend RoboticsSenior AI Research EngineerLed the robot learning stack behind VR teleoperation: from human demonstration to autonomous policy on the robot.
- Mar 2022 – Jun 2024VeridiumComputer Vision ScientistFace biometrics that run on the phone, benchmarked by NIST: landmarks, gaze, head pose, recognition and liveness.
- Sep 2018 – Feb 2022Q-BotResearch EngineerRobots and sensors for retrofitting homes: underfloor insulation robots, a wall-rendering gantry and a home survey device.
open source
Tools other people use.
- gist★ 93Textured mesh from a point cloudStep-by-step MeshLab guide: point cloud to textured mesh.Guide ↗
 repo★ 28stereo-calibStereo calibration, rectification and depth estimation with ChArUco boards.Python ↗
 repo★ 9nerf-toyA 2D toy NeRF: why Fourier feature mapping lets an MLP learn fine detail. On PyPI, Colab demo.Python ↗
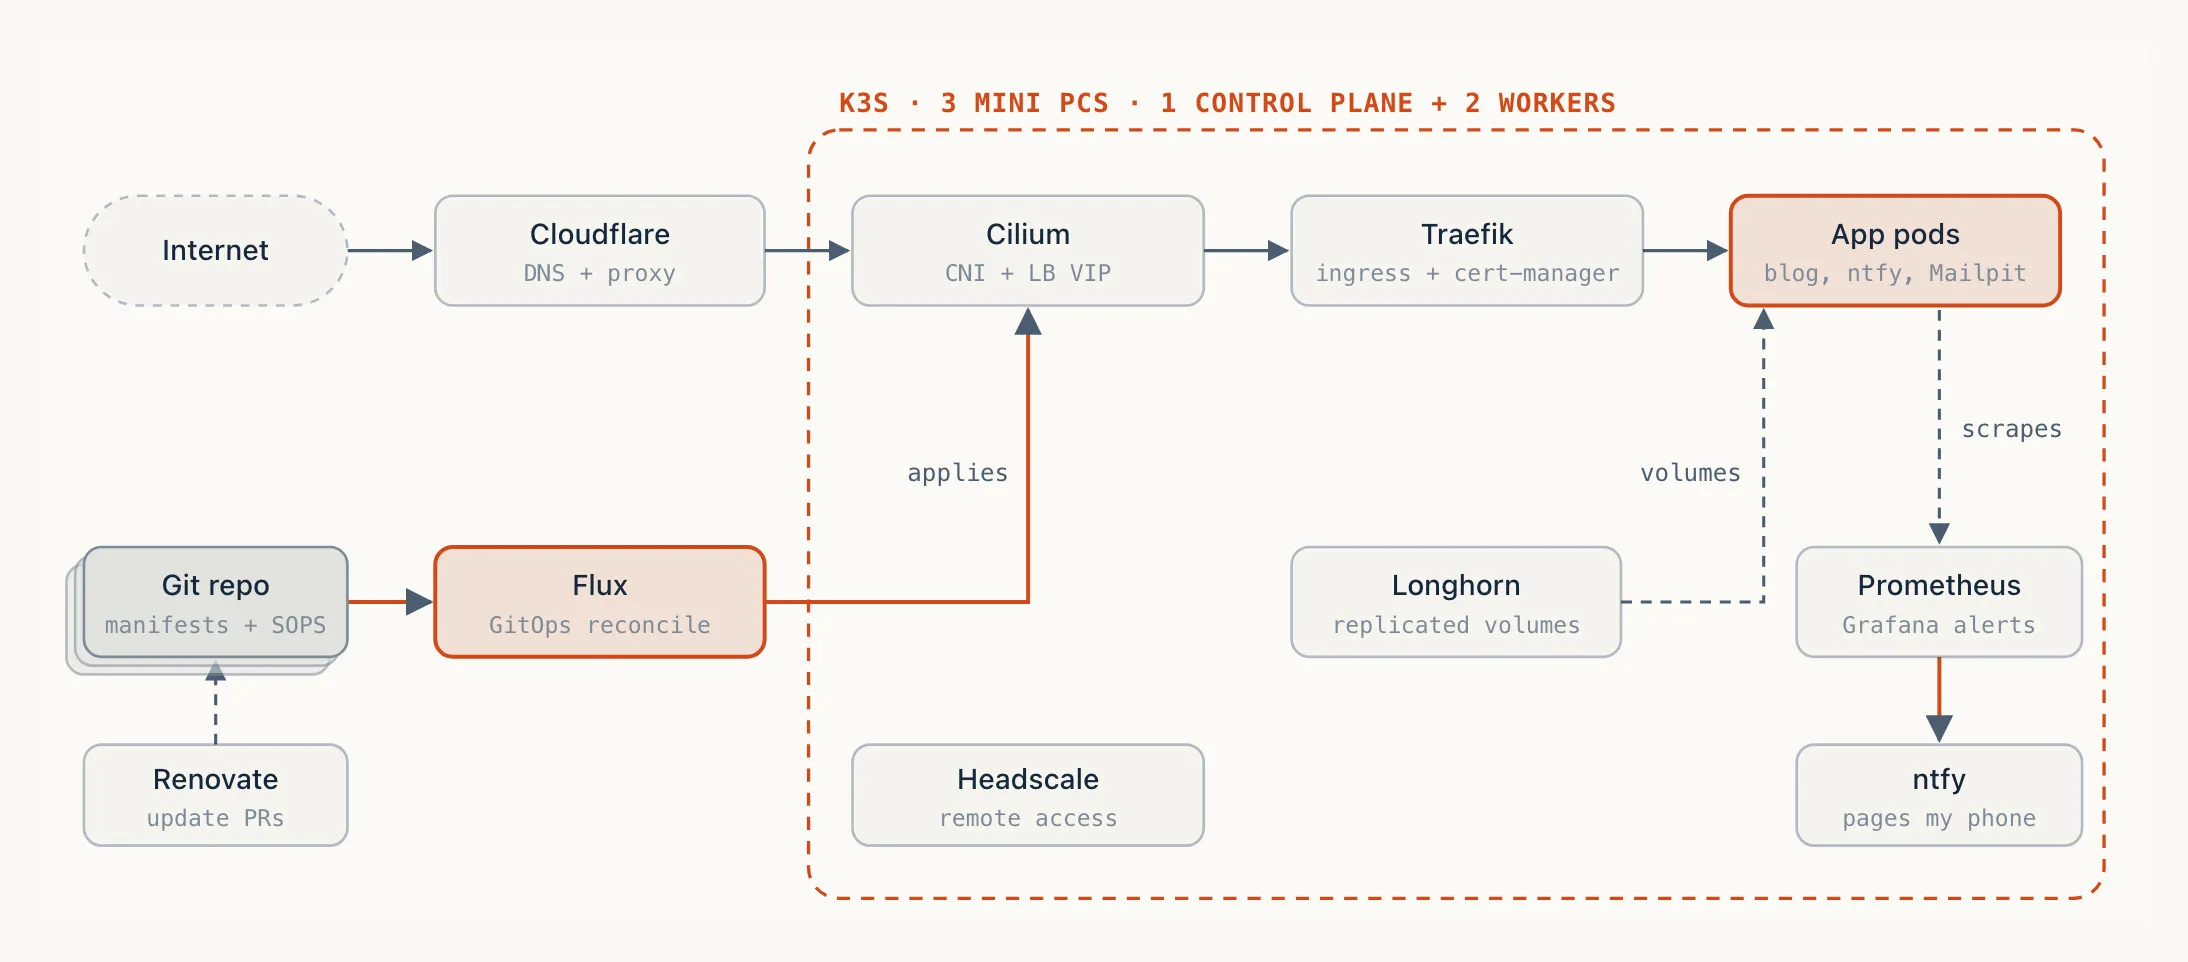 repohomeopsInfrastructure as code for my homelab: k3s, GitOps with Flux, self-hosted services.Makefile ↗
from the notebook
Rigs, drawings and diagrams.
Paper figures, patent drawings and project shots from 2013 to now. Hover to pause.
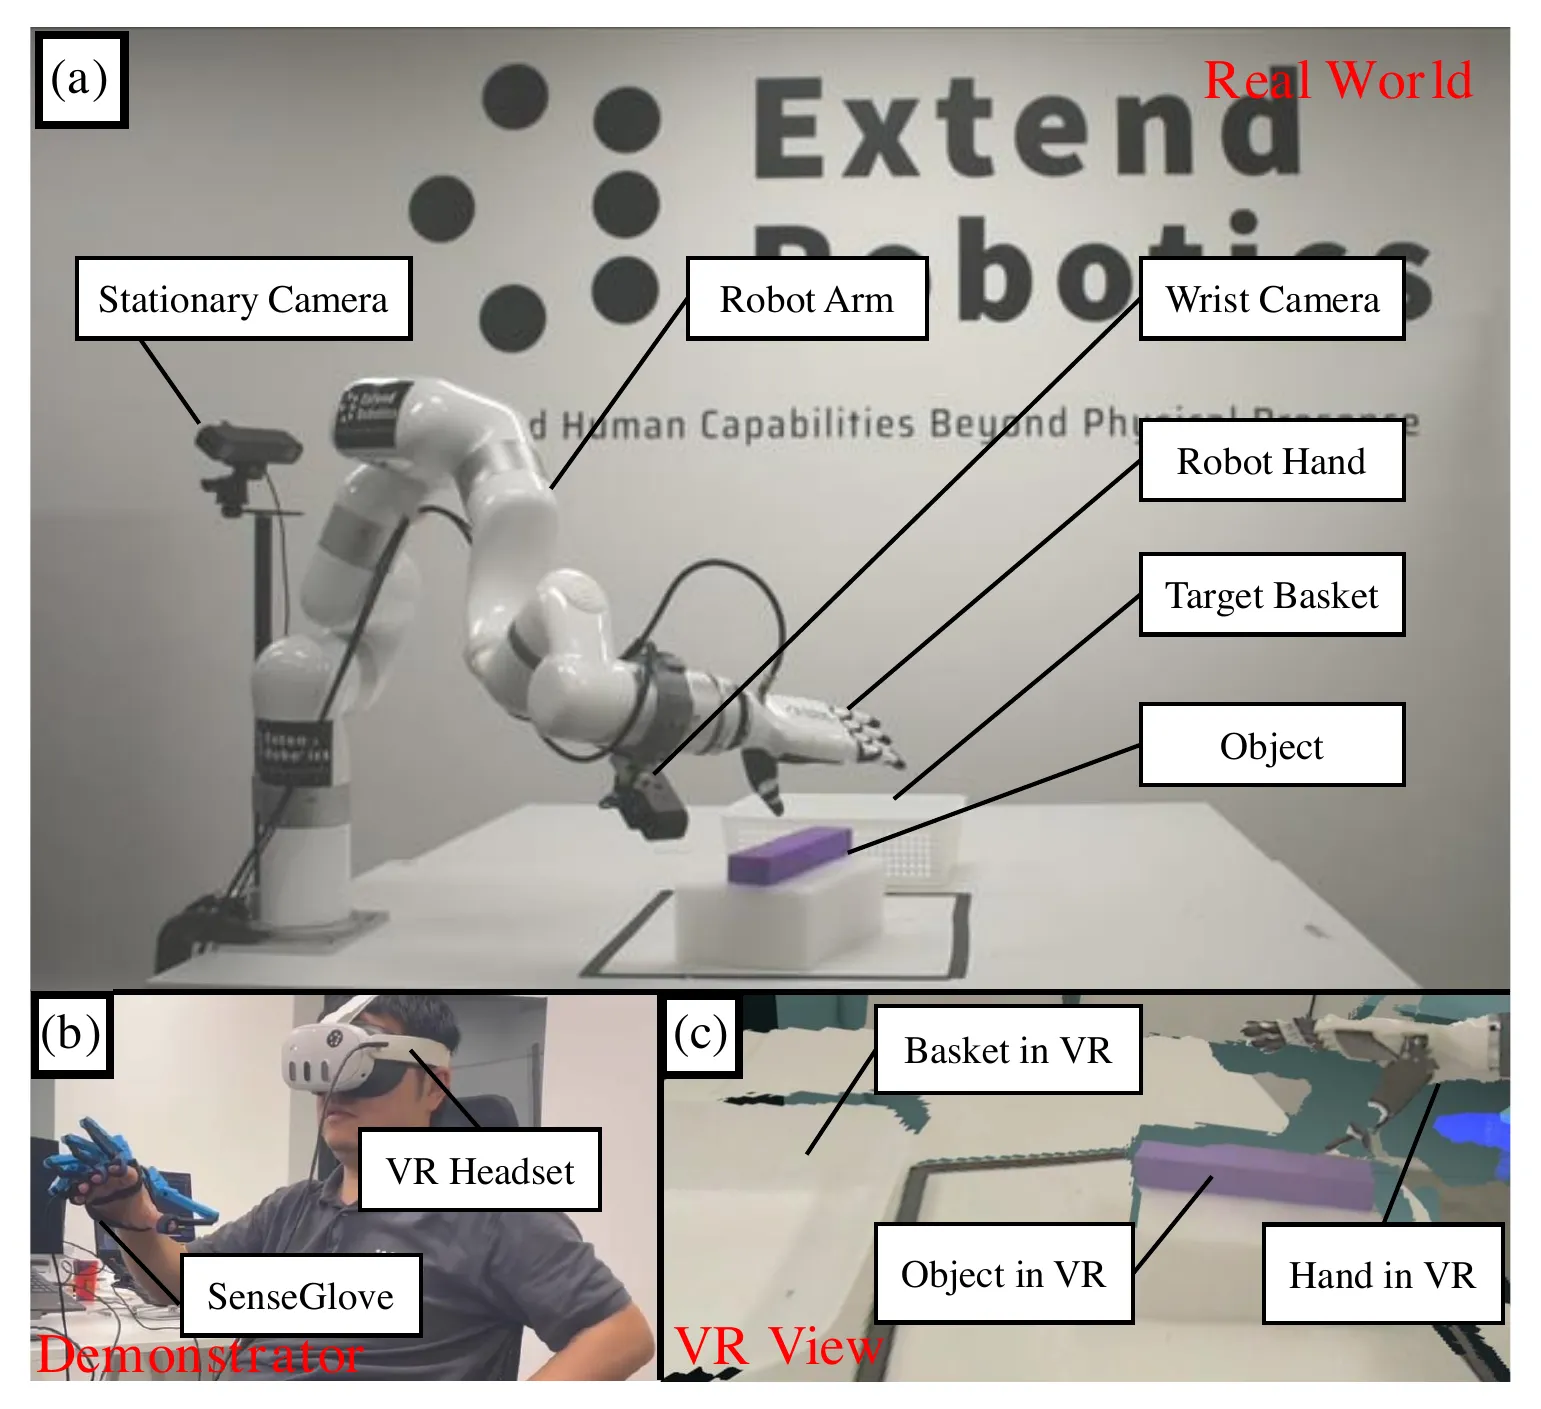 Haptic-ACT teleop rigExtend · 2025
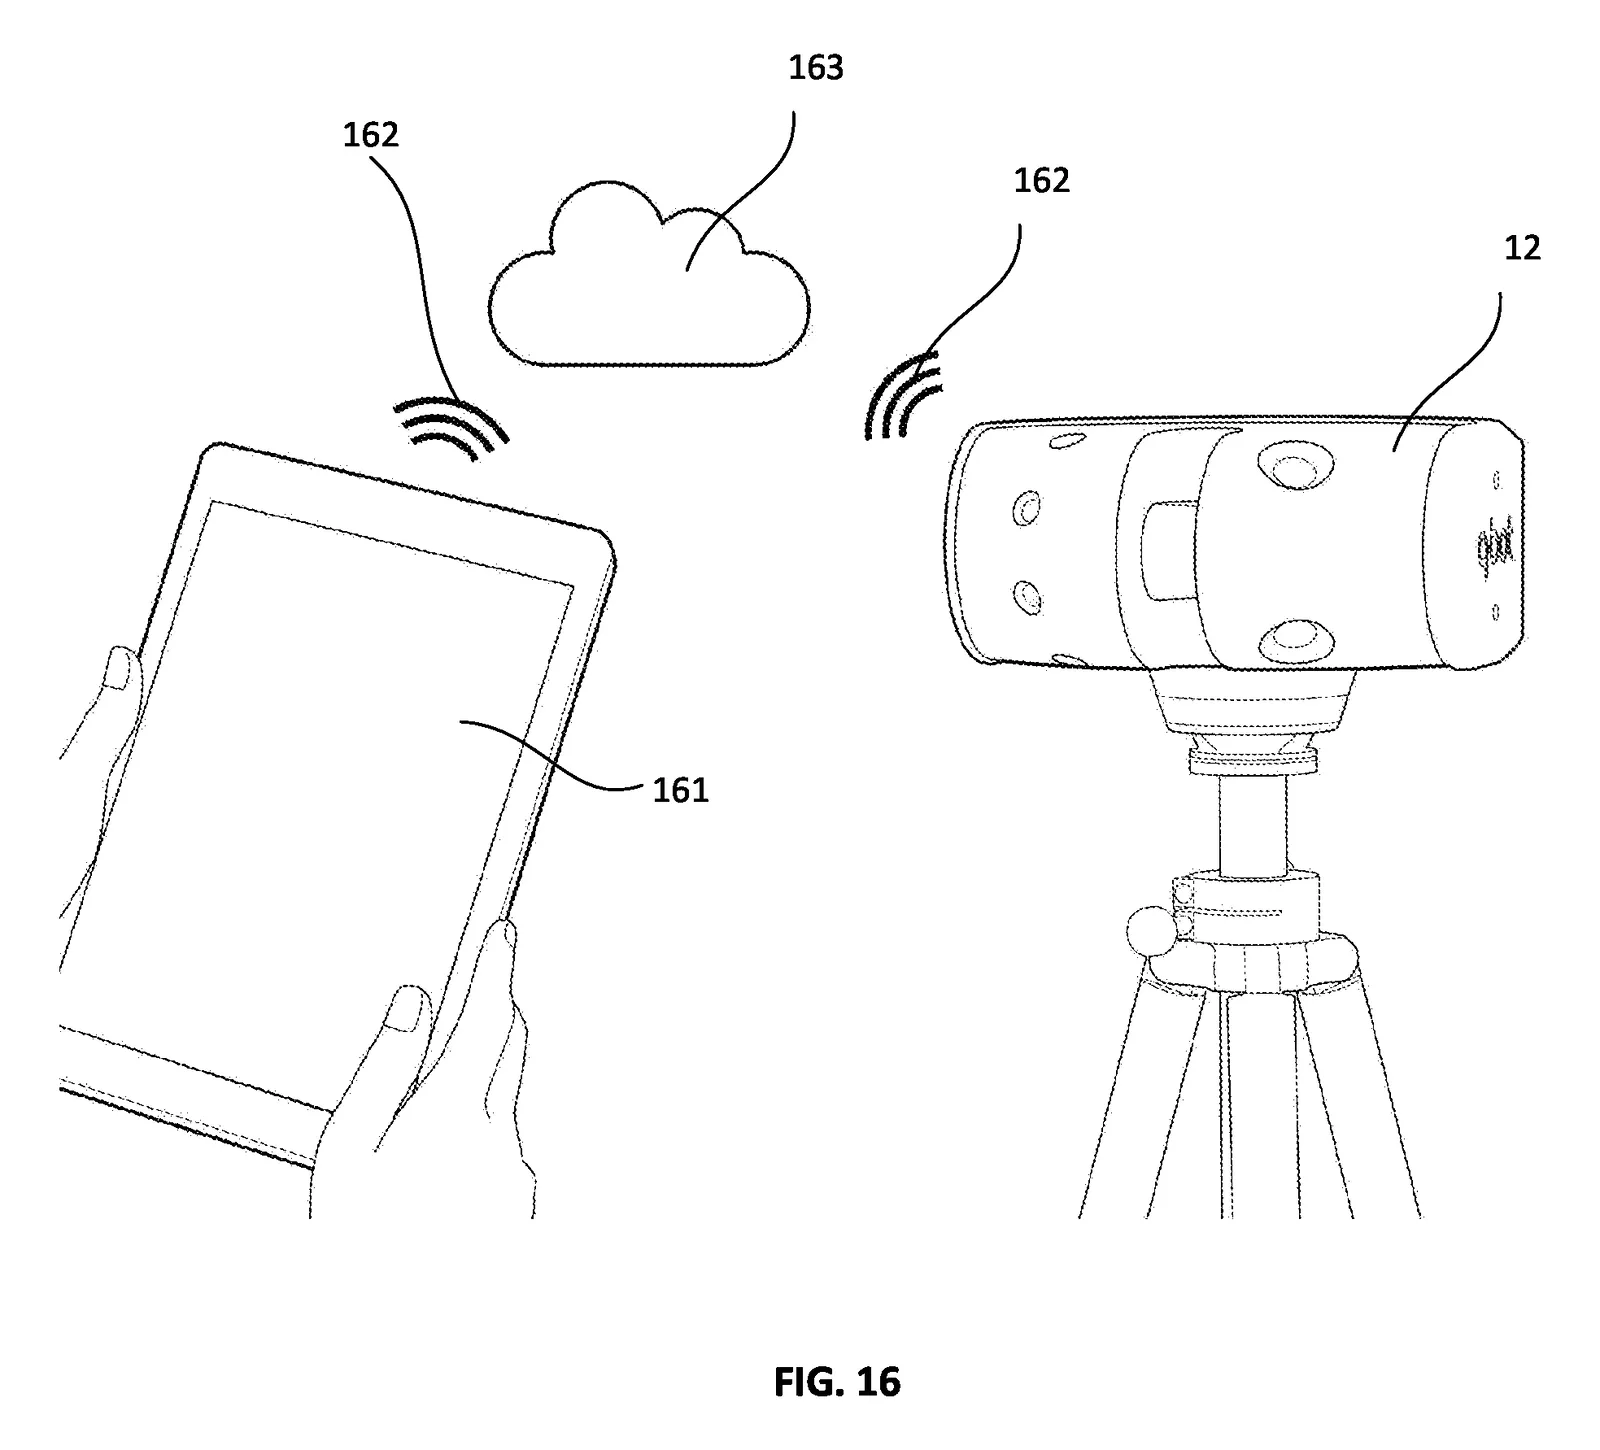 Home Health Monitor, patent drawingQ-Bot · 2022
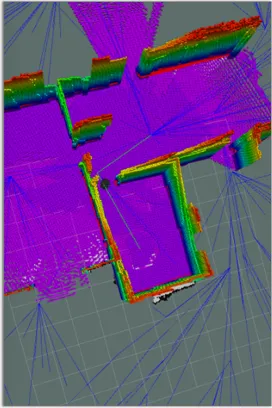 Frontier exploration on OctoMapMSc · 2017
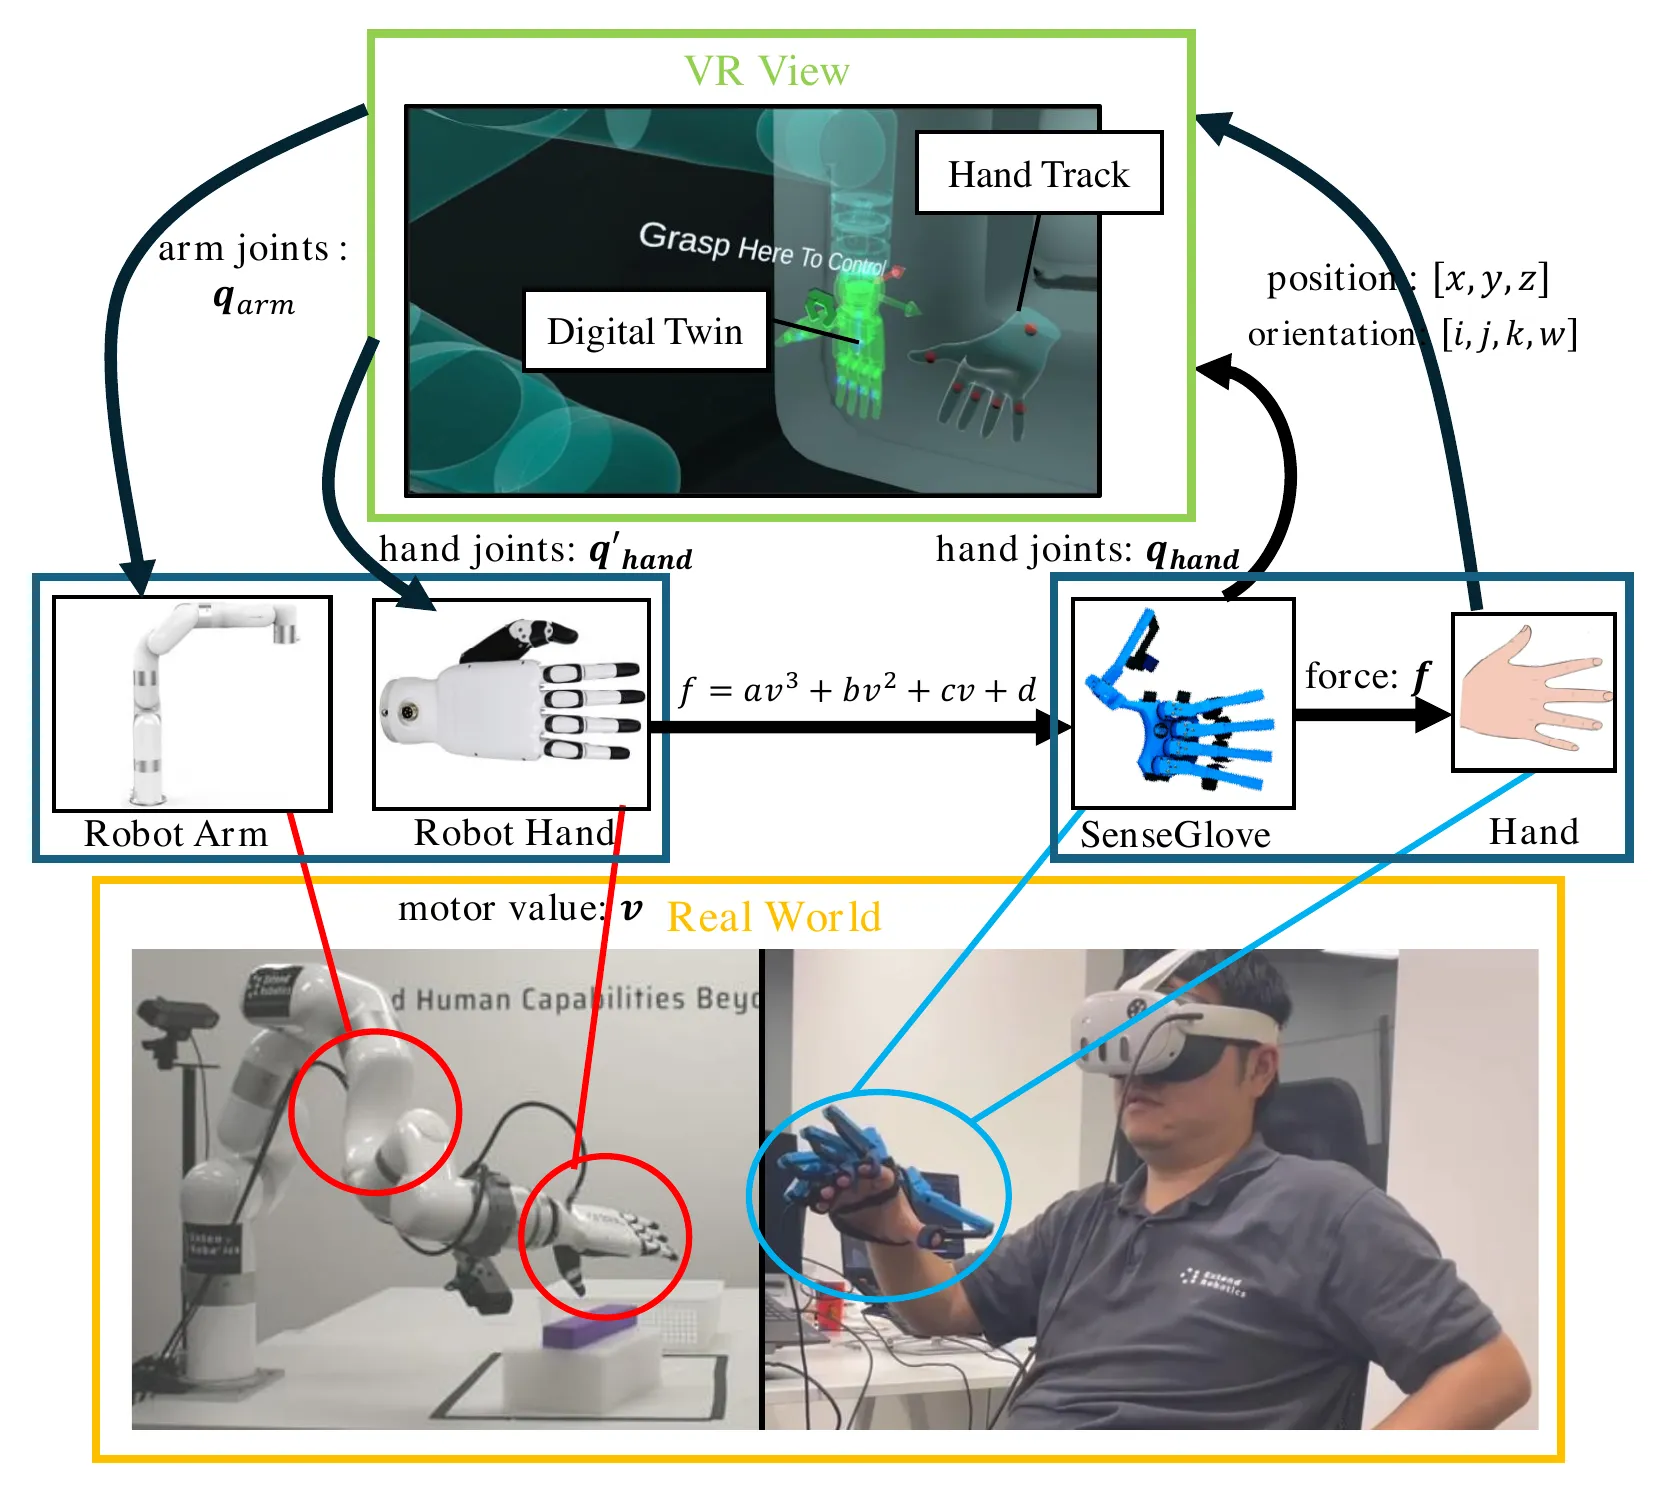 Haptic-ACT teleop loopIROS · 2025
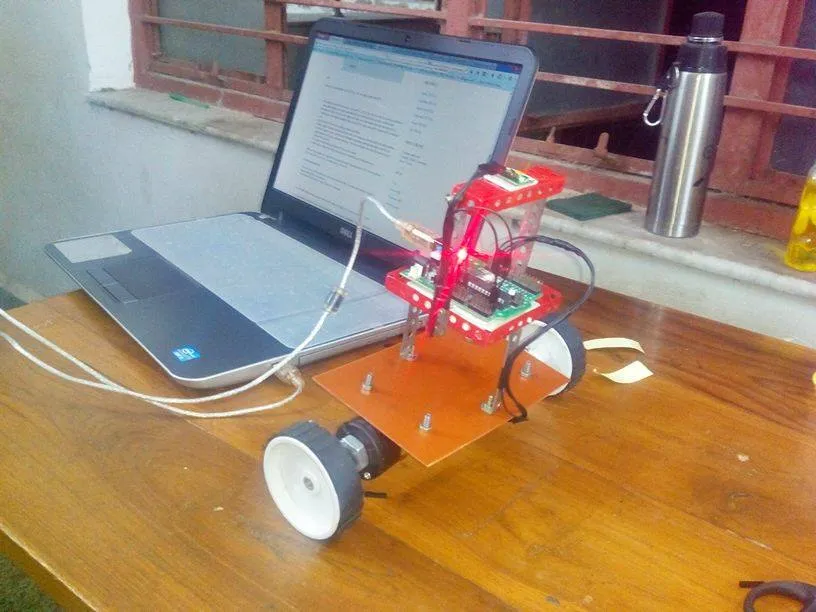 Self-balancing robotB.Tech · 2013
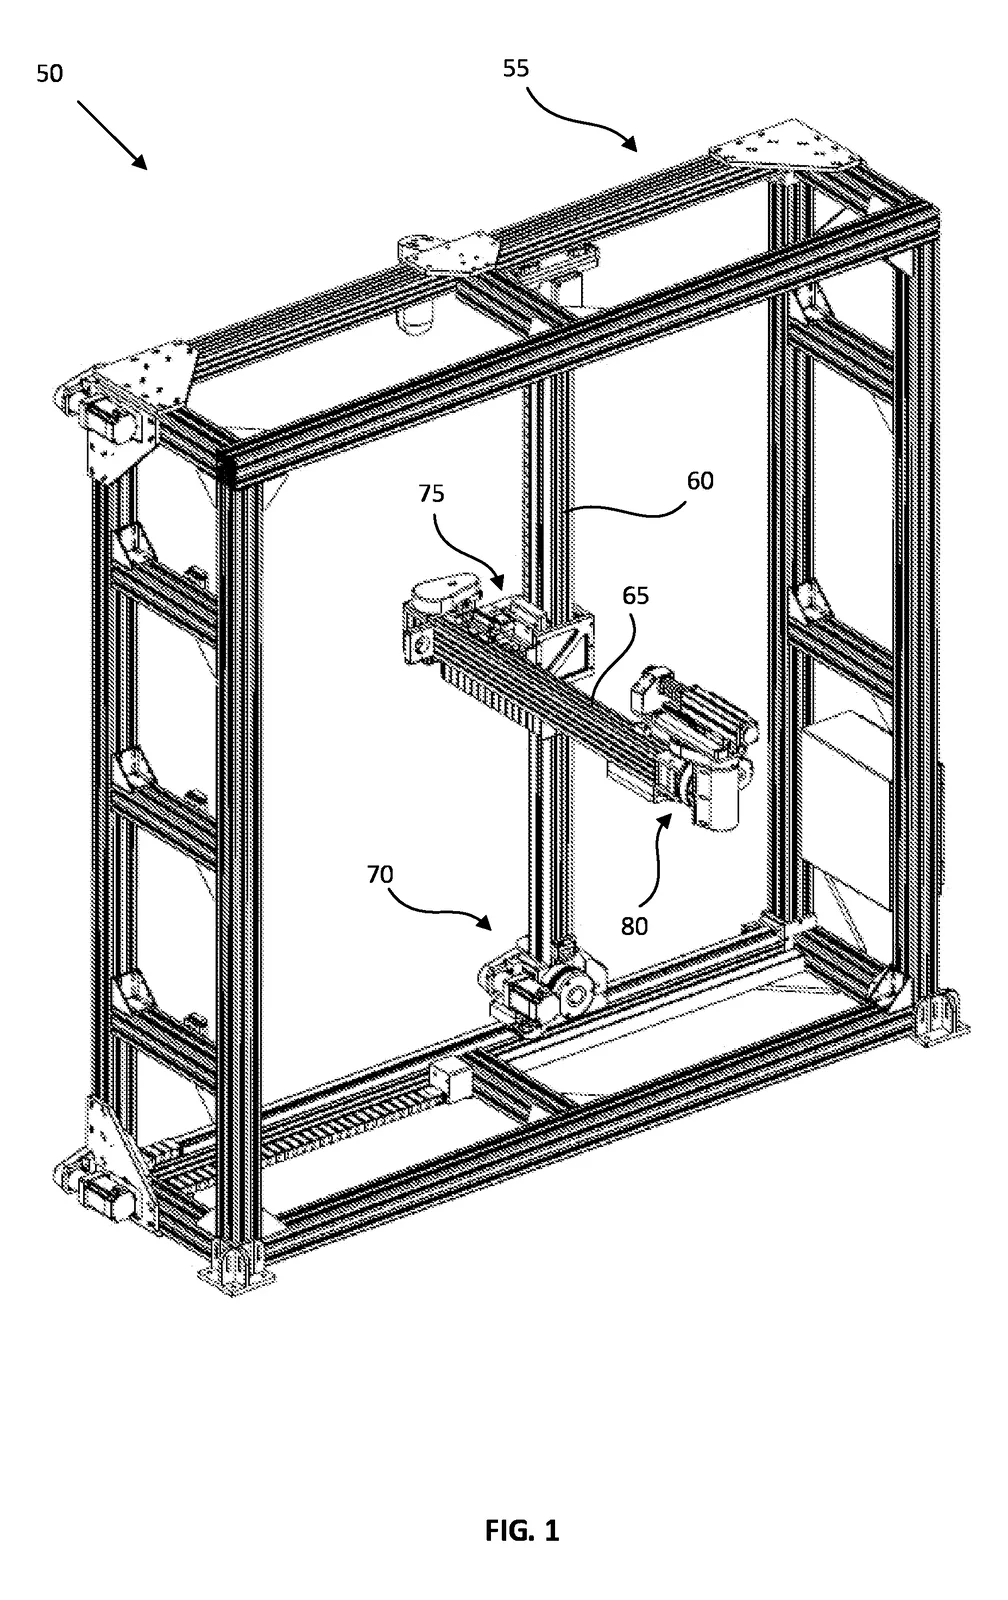 SAWS gantry, patent drawingQ-Bot · 2024
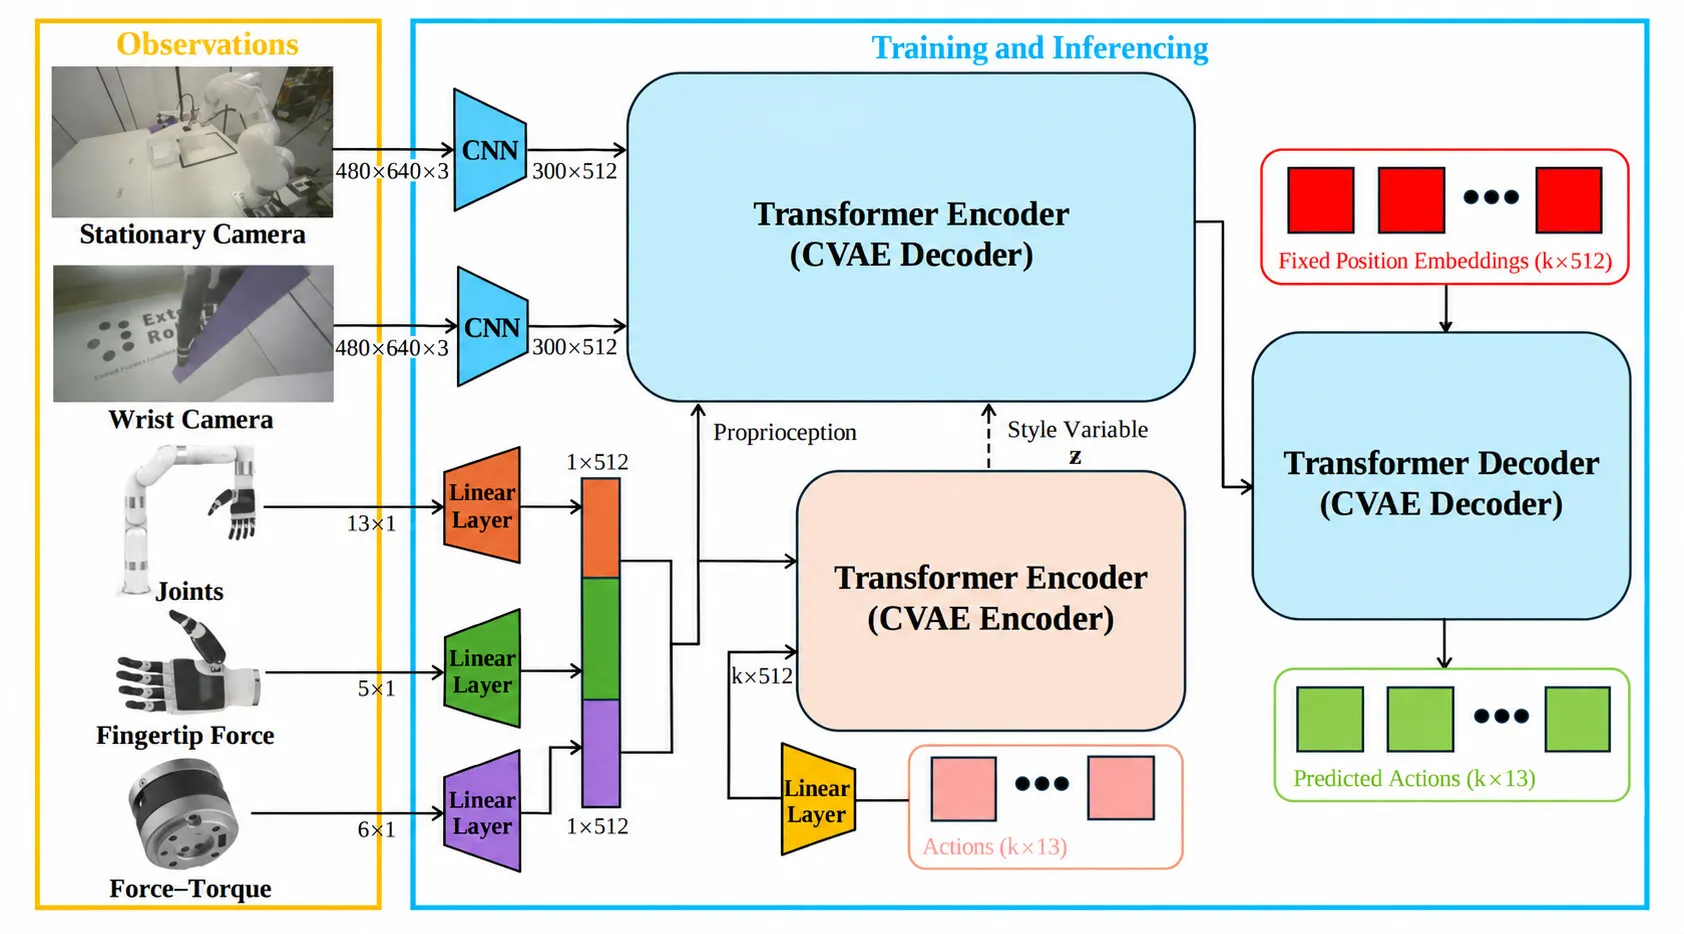 Haptic-ACT architectureIROS · 2025
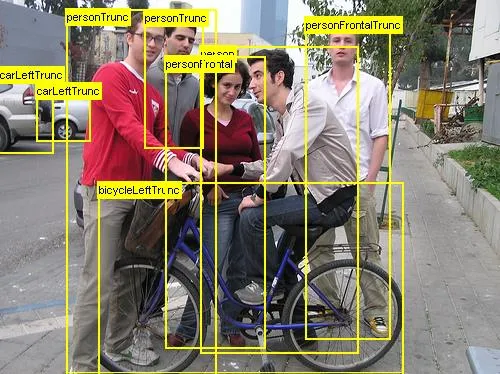 Object recognition, Pascal VOCMSc · 2017
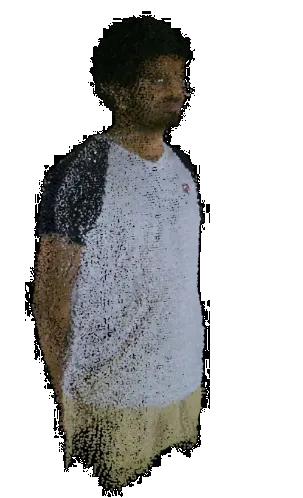 3D human body scanMSc · 2017
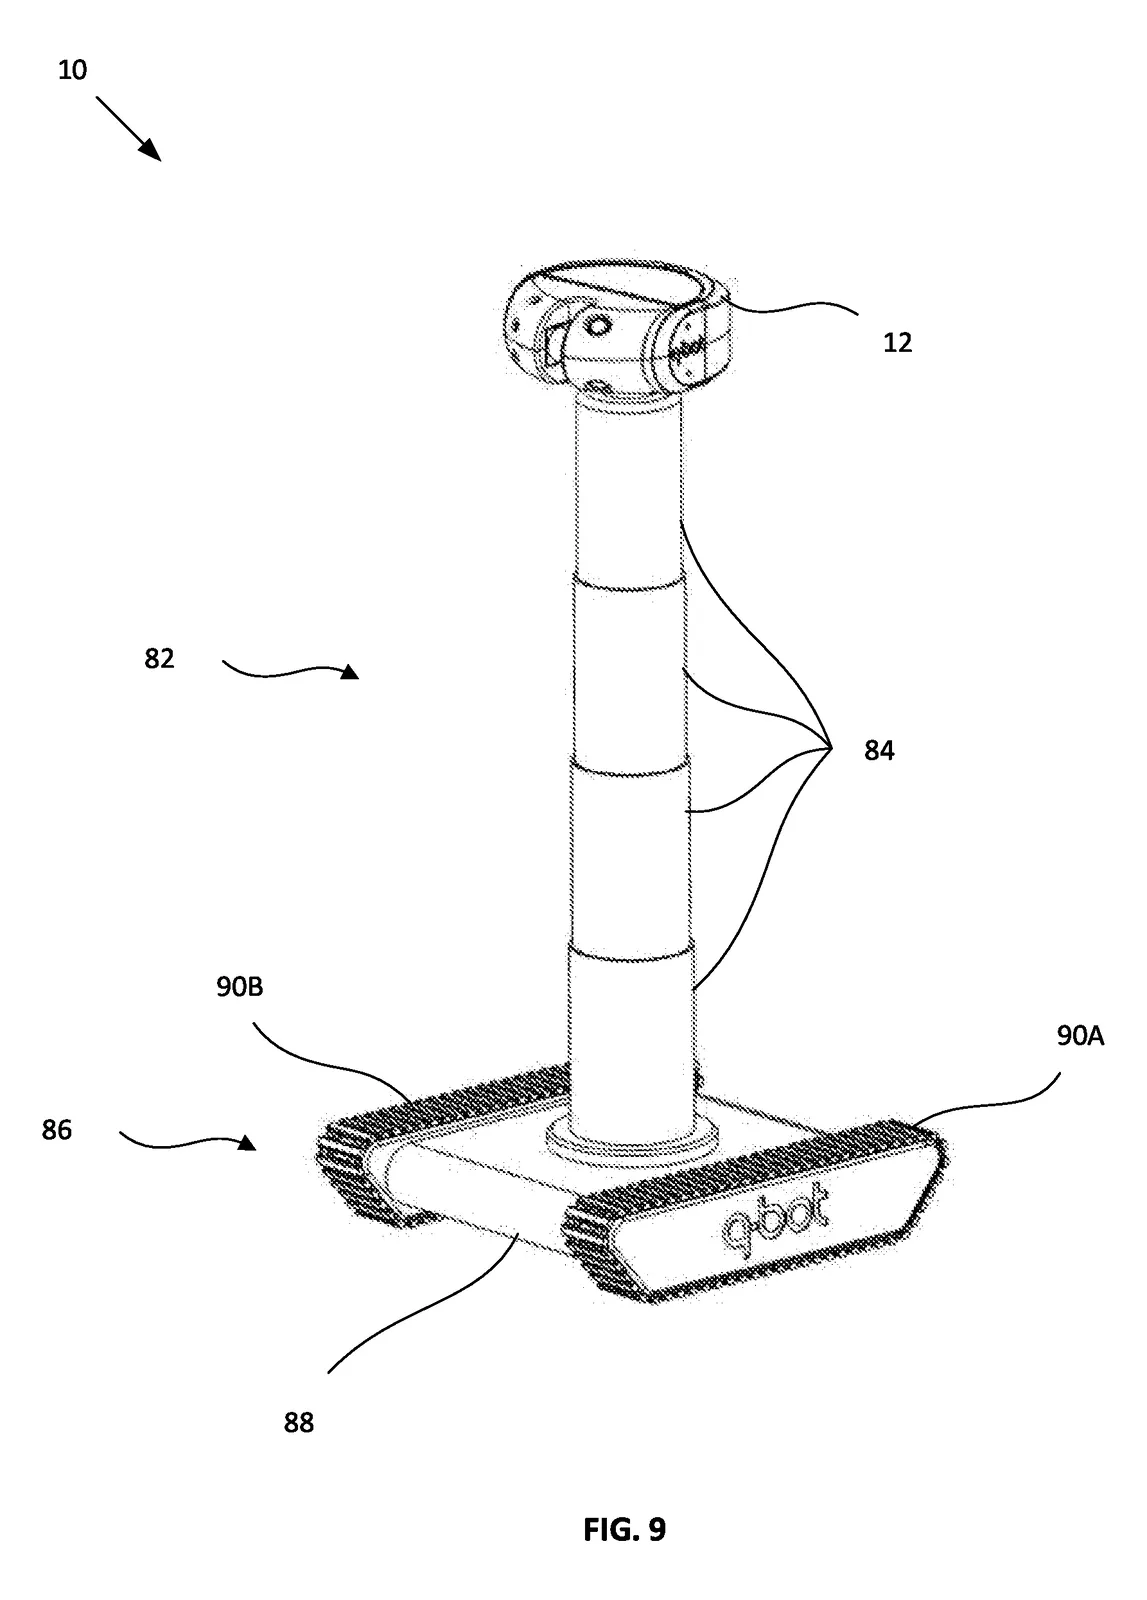 Tracked sensor mast, patent drawingQ-Bot · 2022
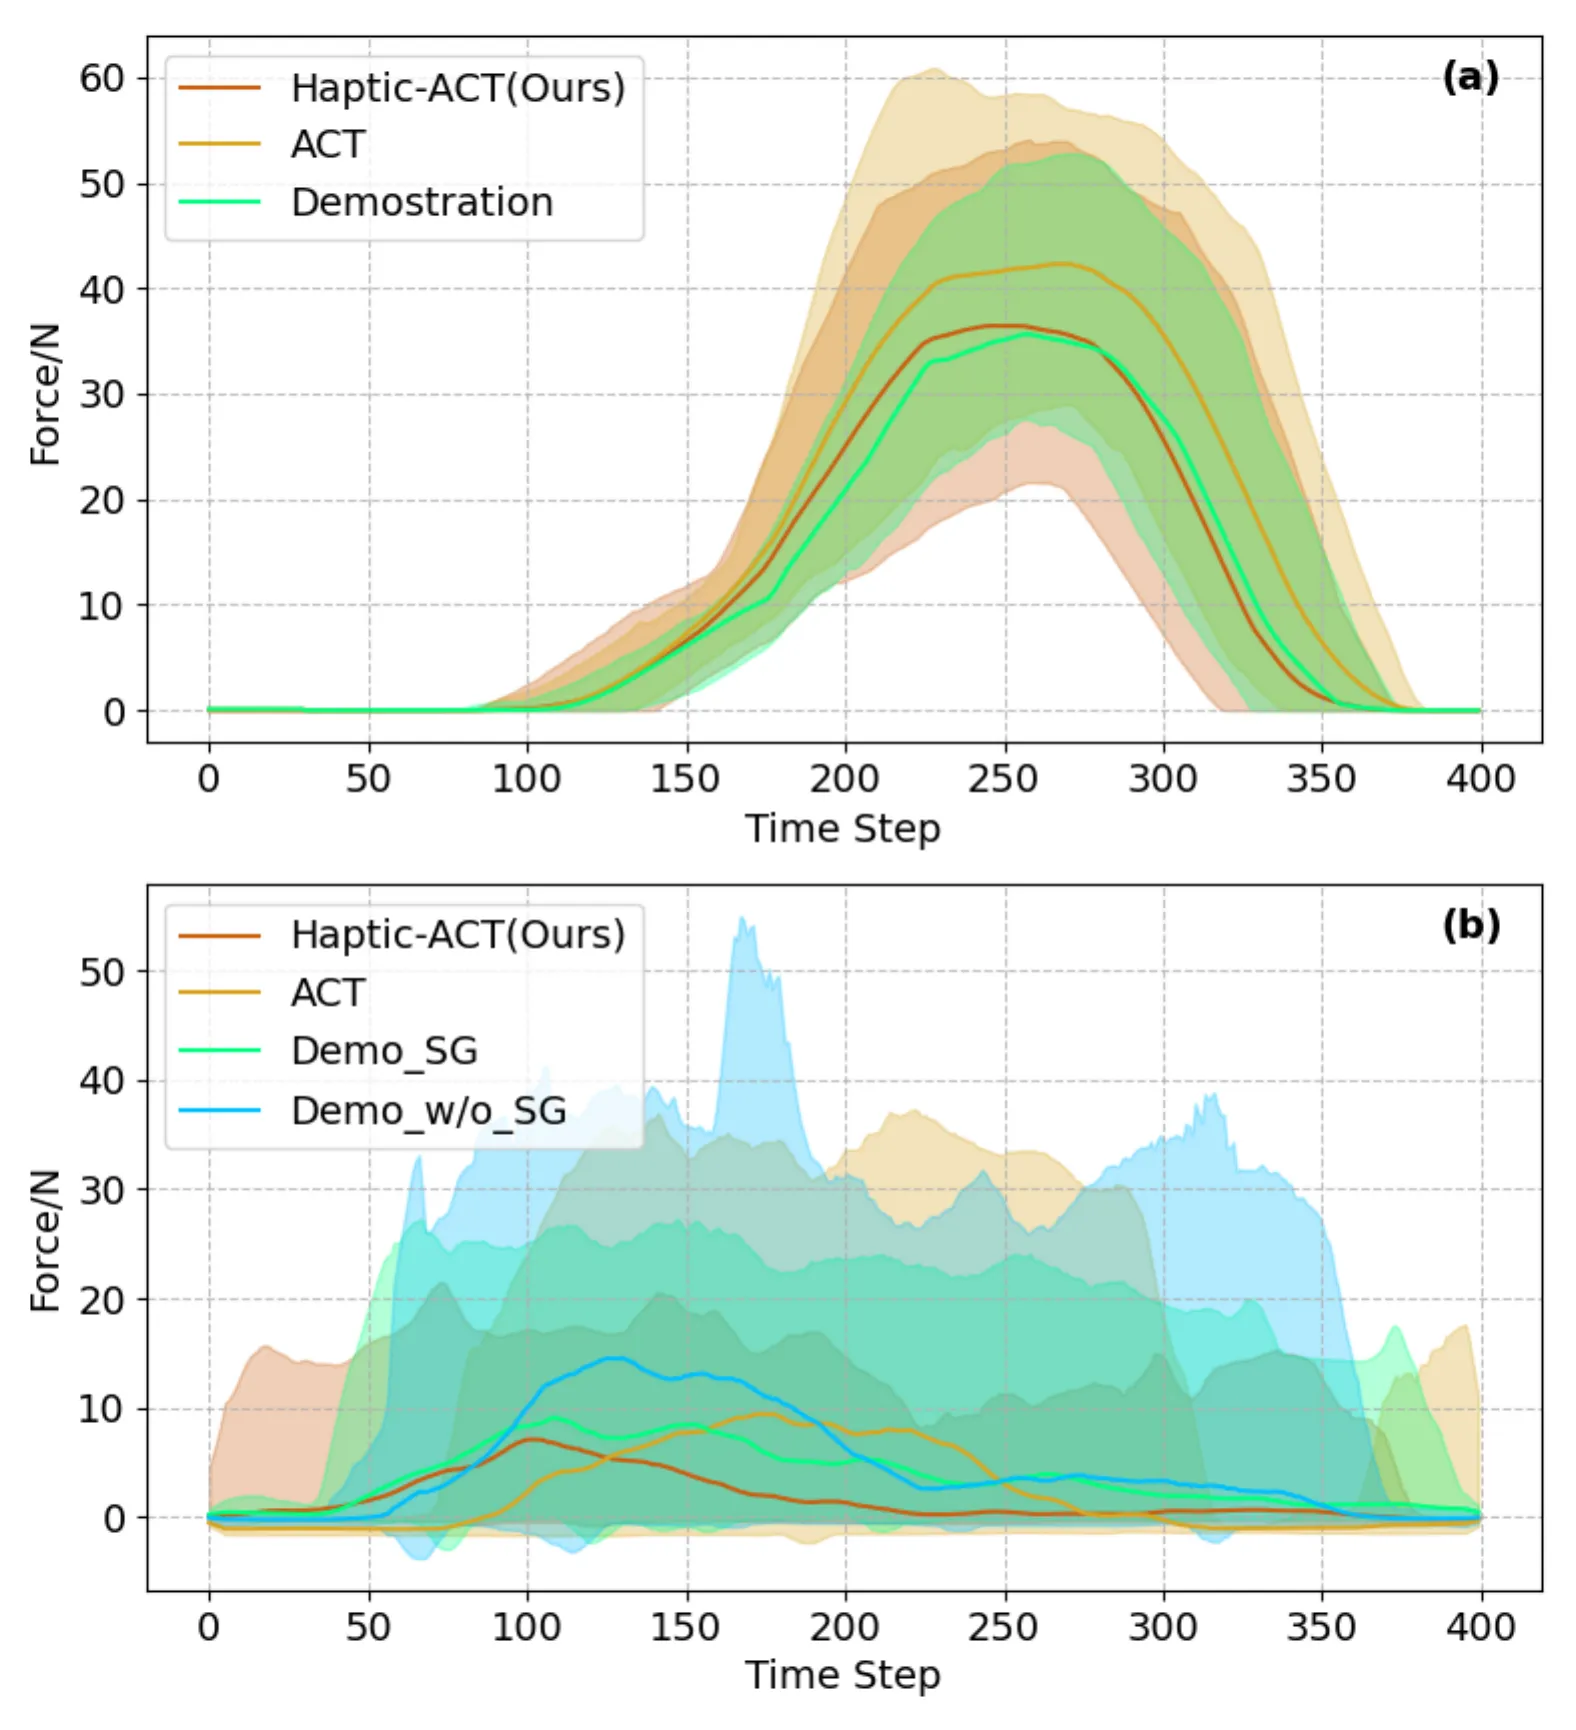 Fingertip force, sim vs realIROS · 2025
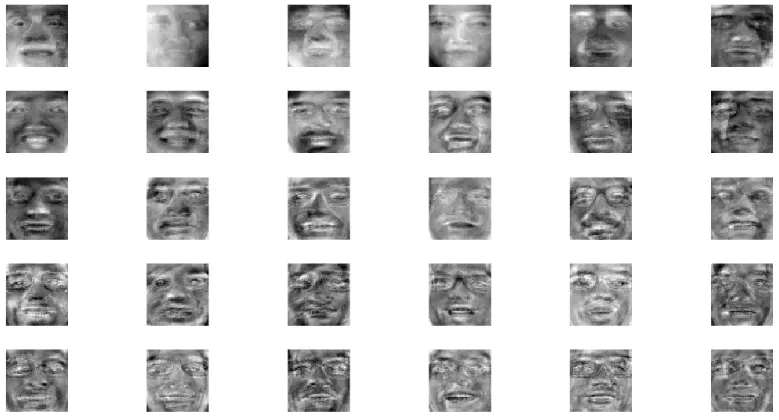 EigenfacesMSc · 2017